

UNISI Dept. of Information Engineering and Mathematical Sciences
UNIVERSITY OF SIENA
Human Centered Robotics Group del SIRSLab
Dept. of Information Engineering and Mathematical Sciences
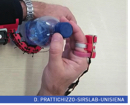
The Sixth finger and the wearable haptic devices
Sixth Finger: a wearable robotic extra finger to compensate the grasping capability in stroke subjects to be worn on the paretic forearm by means of an elastic band, coupled with a vibrotactile ring interface on the healthy hand. The robotic finger and the paretic hand act like the two parts of a gripper working together to grasp the object. The user is able to control the flexion/extension of the robotic finger through a switch placed on the ring, while being provided with vibrotactile feedback about the forces exerted by the sixth finger.
Wearable Haptic interfaces: wearable devices to reproduce the sense of touch enabling novel forms of communication between humans and robots. The challenge is to grant extreme wearability a key element for natural interaction.